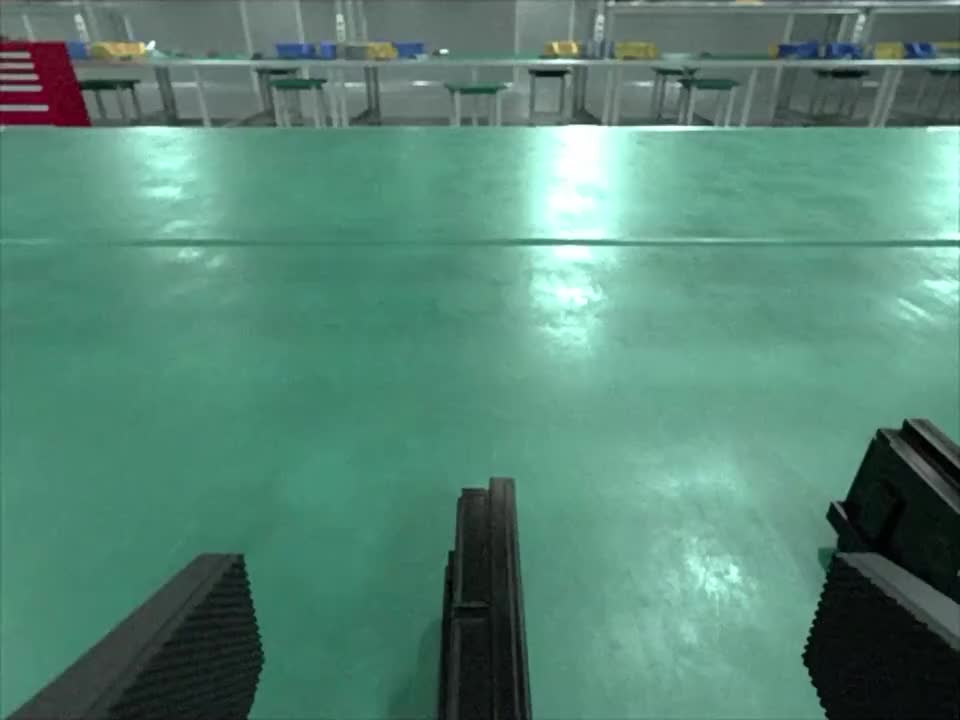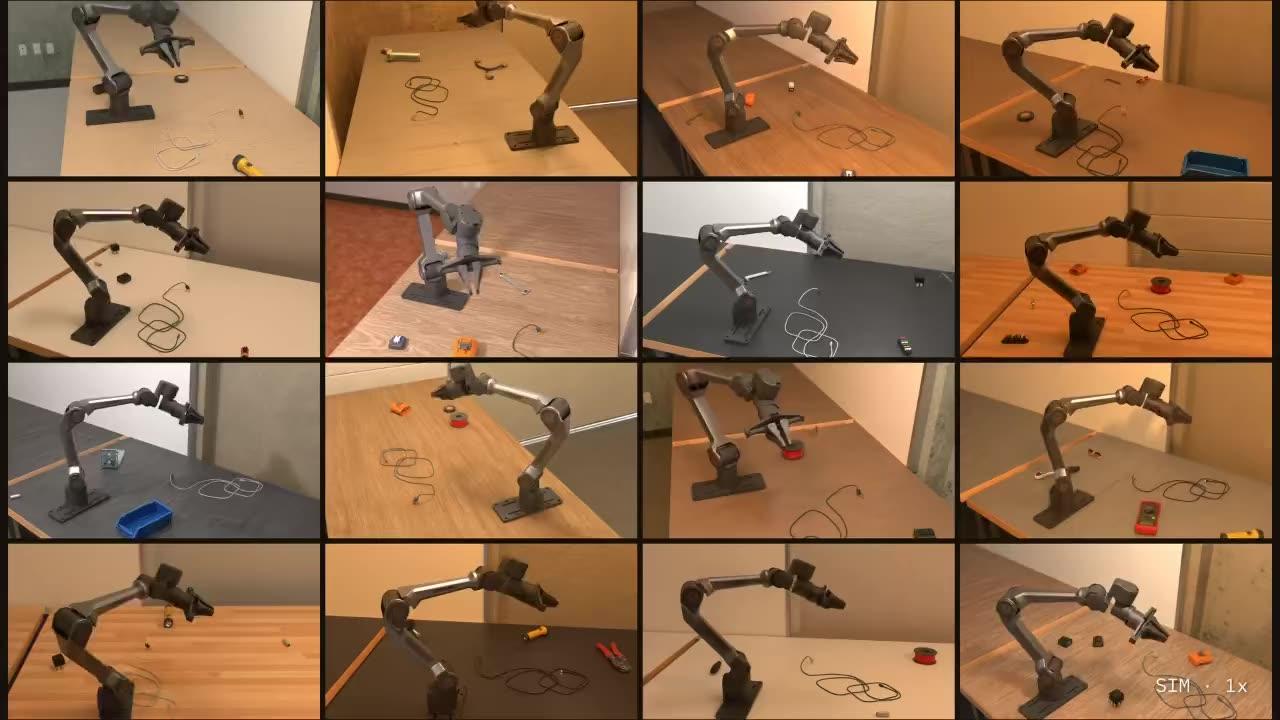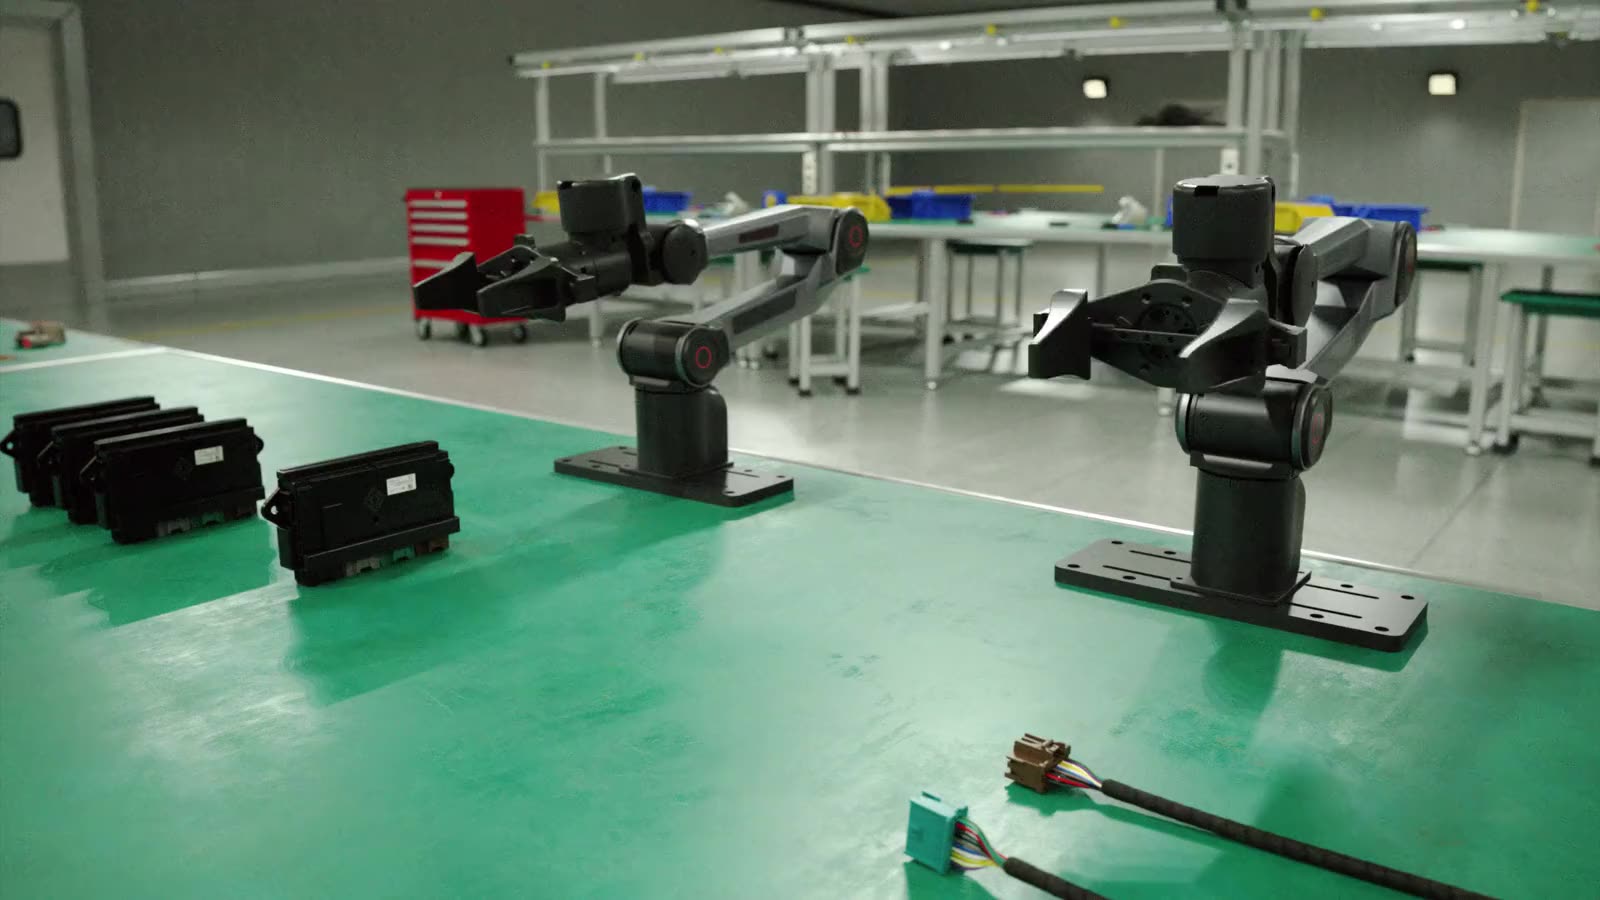
Take the hardware you’re designing for a test drive.
Determining optimal sensor hardware and its placement shouldn’t have to wait on your robot vendor or internal hardware teams. De-risk embodiment and end-effectors before procurement by comparing performance across competing designs, before you can physically obtain them, and use high-fidelity sensor modeling with desired noise and bias to settle sensor selection and placement.